ROBOTIC ARM / NEW MEMBER WORKSHOP / 2025
ISRC // VISUAL RECORD
01 / Overview
A compact manipulation project focused on servo actuation and mechanical system integration.
Current State
✓Arm structure assembled
✓Joint actuation tested
✓Basic sequences implemented
Next Iteration
○End-effector redesign
○Motion refinement
○Platform integration
Build Evidence
From bench
to field.
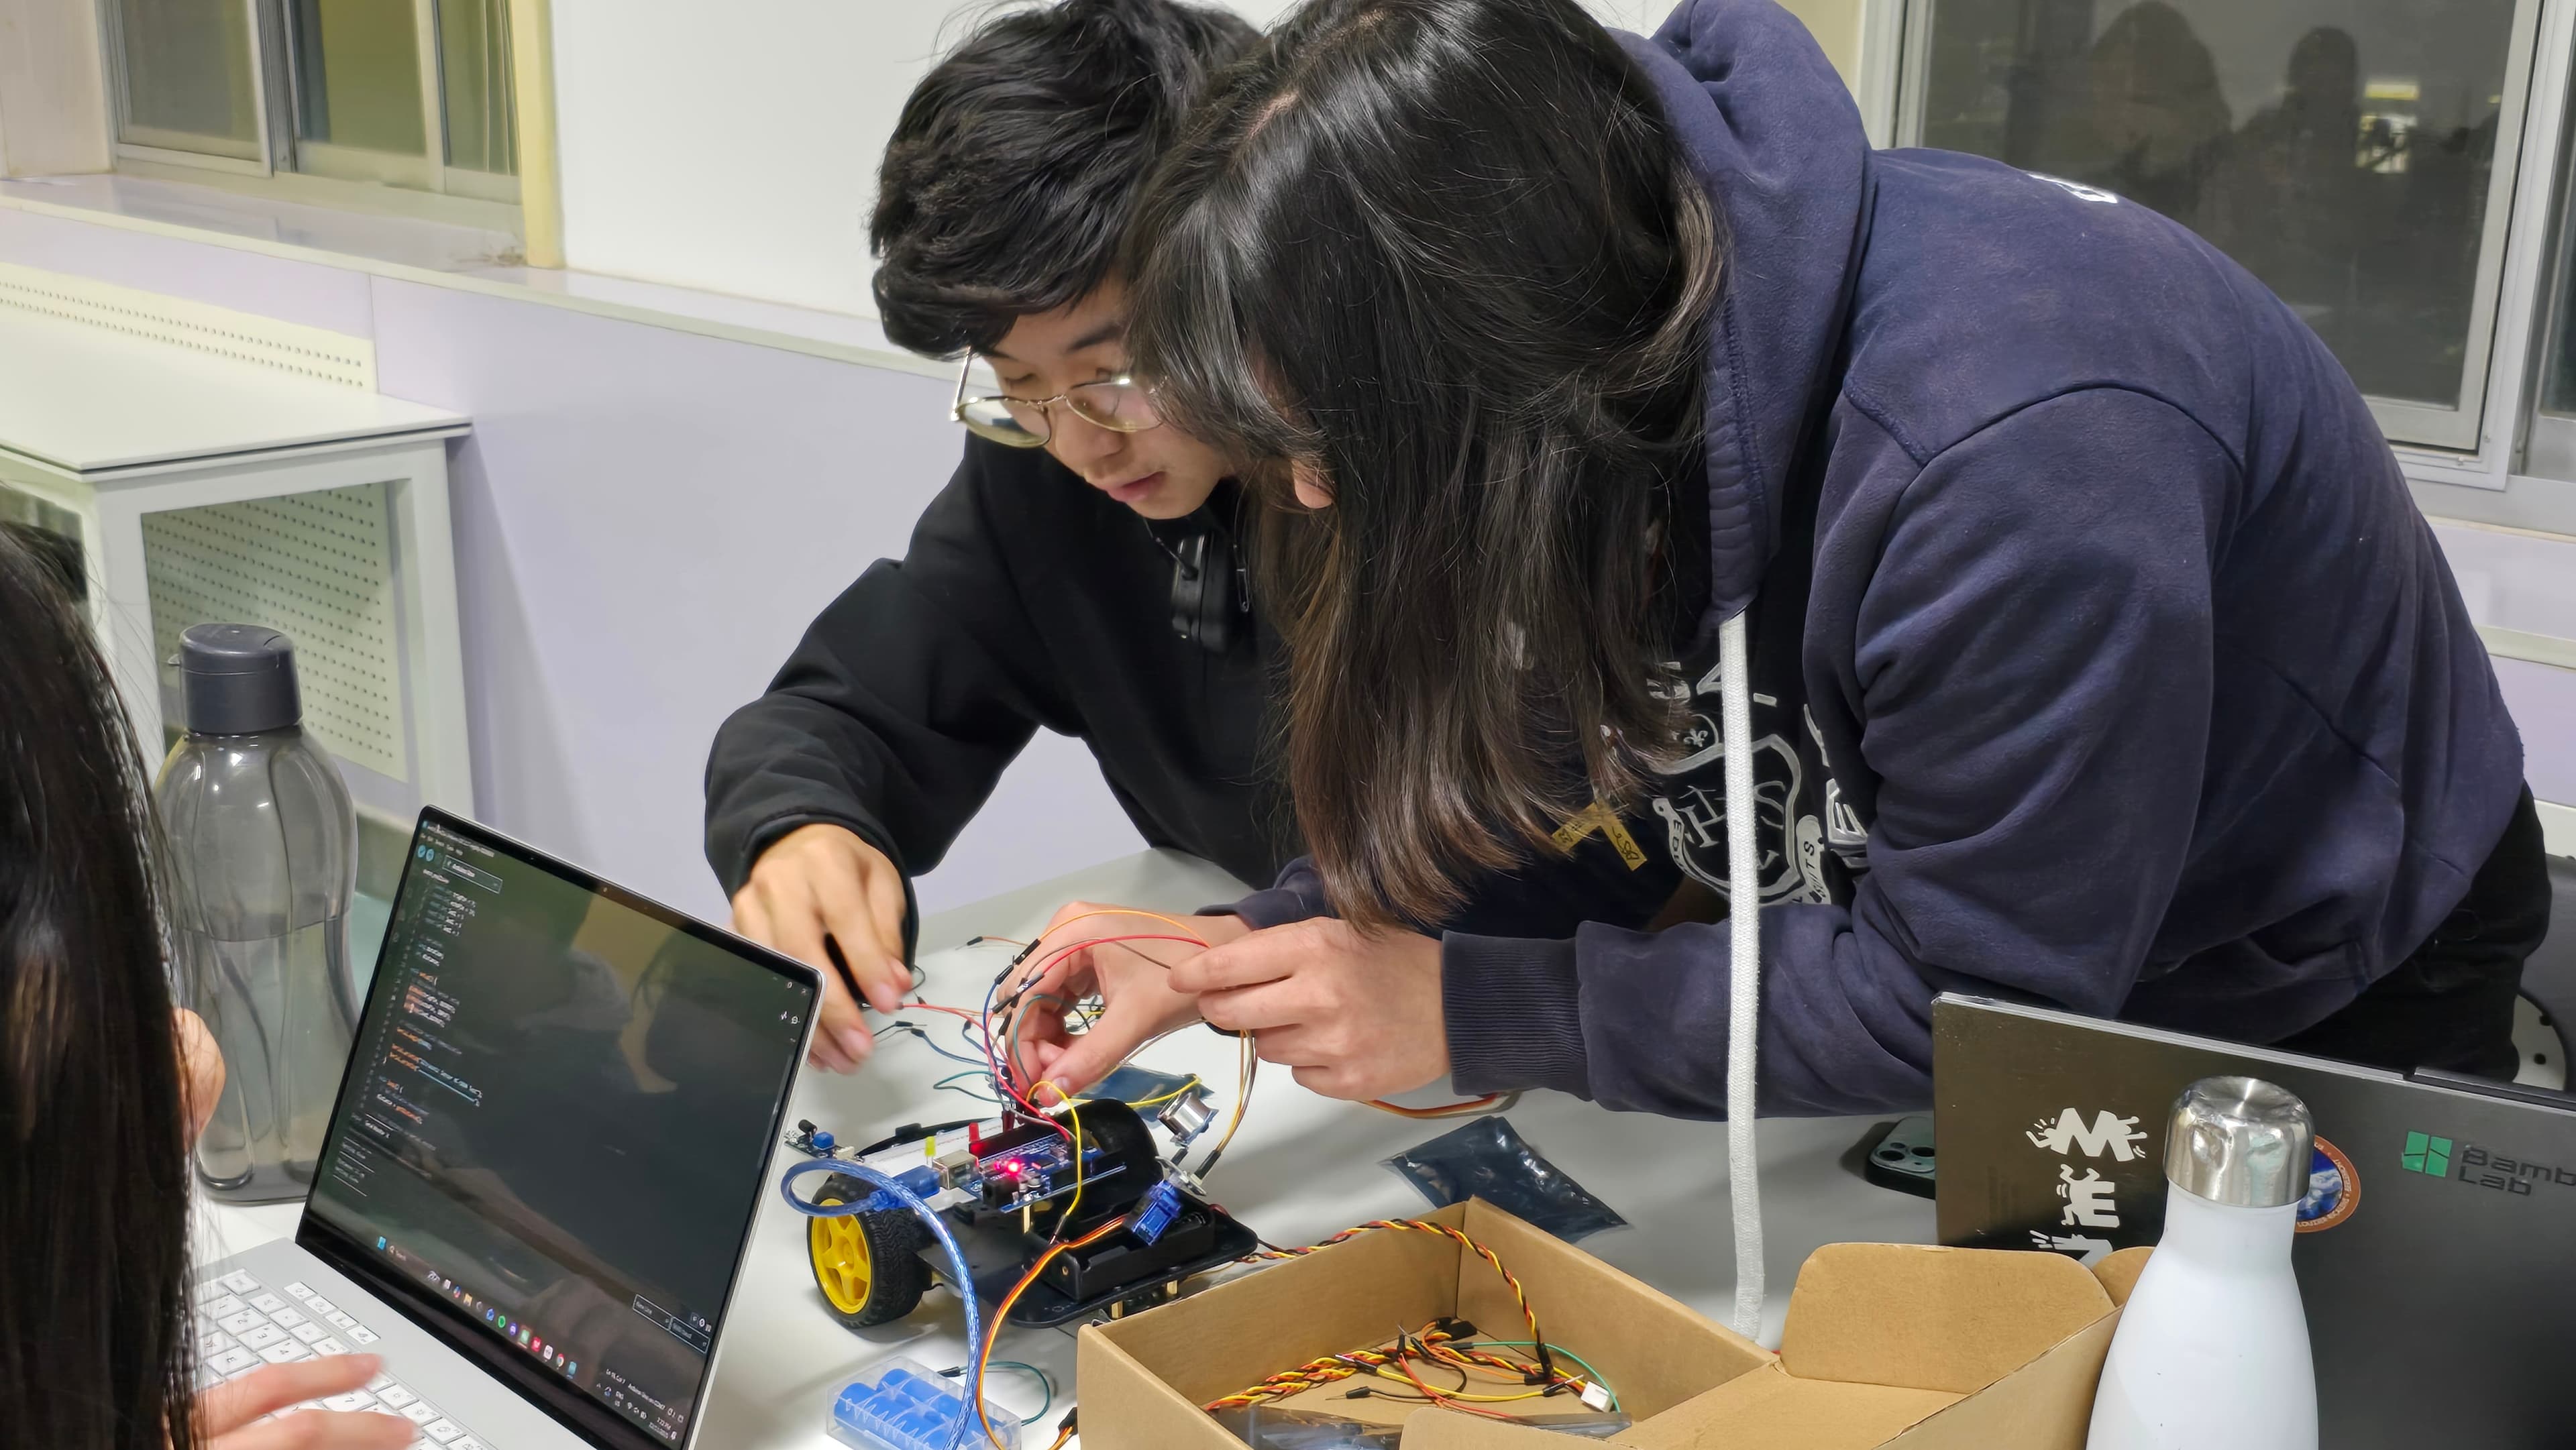
Selected archive frames document the physical system and its development context. They do not imply completion of work still listed below.
Training / Workshop / 2025
System Definition
Hardware
01
Mechanical
Link design
Joint brackets
End effector
02
Actuation
Servo joints
Power distribution
03
Control
Sequence control
Position commands
Build Record
Development timeline
V 0.1
Linkage Design
CompleteV 0.2
Joint Assembly
CompleteV 0.3
Motion Sequences
CurrentV 0.4