← Project Index
ISRC / H01
17-DOF Humanoid Robot
Prototype Development
17 DOFESP32Bus ServoMotion Control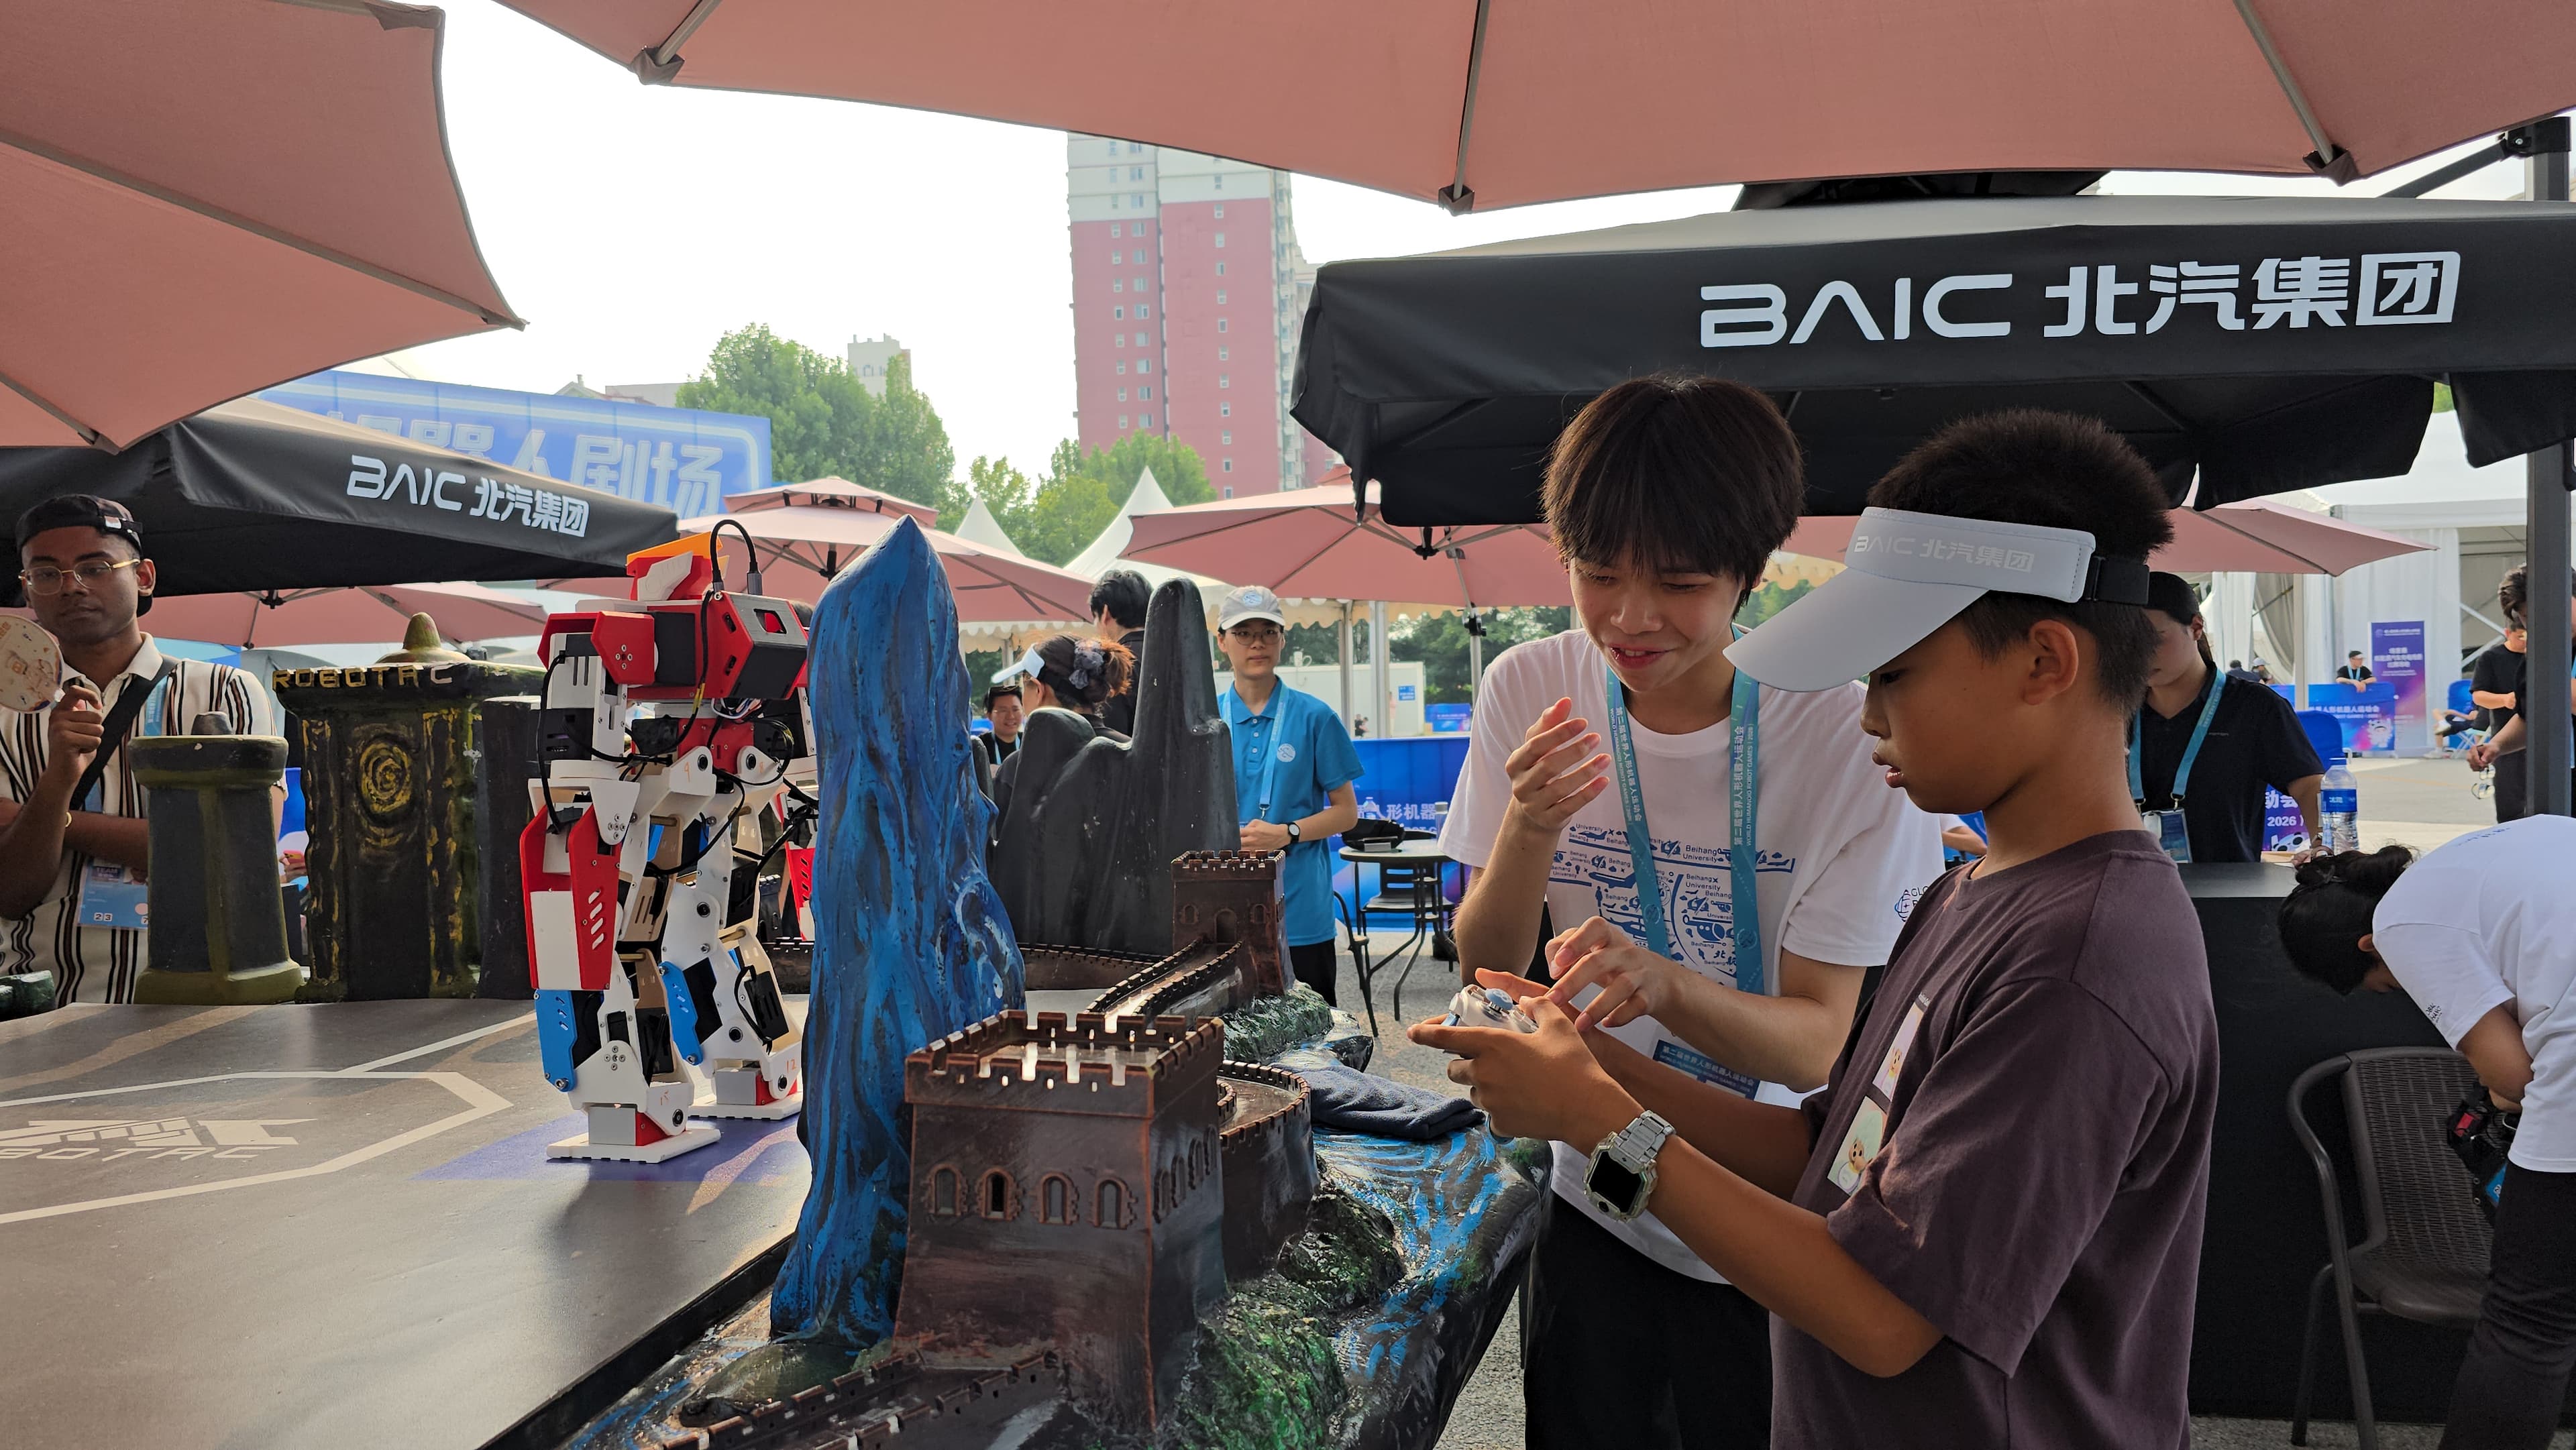
17-DOF HUMANOID / LAB ASSEMBLY / 2026
ISRC // VISUAL RECORD
01 / Overview
A small humanoid platform developed for robotics competition and technical exploration.
Current State
✓Initial assembly
✓Servo control
✓Basic motion
Next Iteration
○Balance algorithm
○IMU feedback
○Stable walking
○Motion optimization
Build Evidence
From bench
to field.
Selected archive frames document the physical system and its development context. They do not imply completion of work still listed below.
World Games / Team / 2026
System Definition
Hardware
01
Mechanical
Structure design
3D printed parts
Joint optimization
02
Actuation
Bus servo system
03
Control
ESP32
Motion control
Build Record
Development timeline
V 0.1
Mechanical Assembly
CompleteV 0.2
Servo Communication
CompleteV 0.3
Basic Motion
CompleteV 0.4